Preview
5 examples in this sample pack. Short clips below are cut from the actual capture; the full pack is delivered from Realset's bucket with temporary credentials.
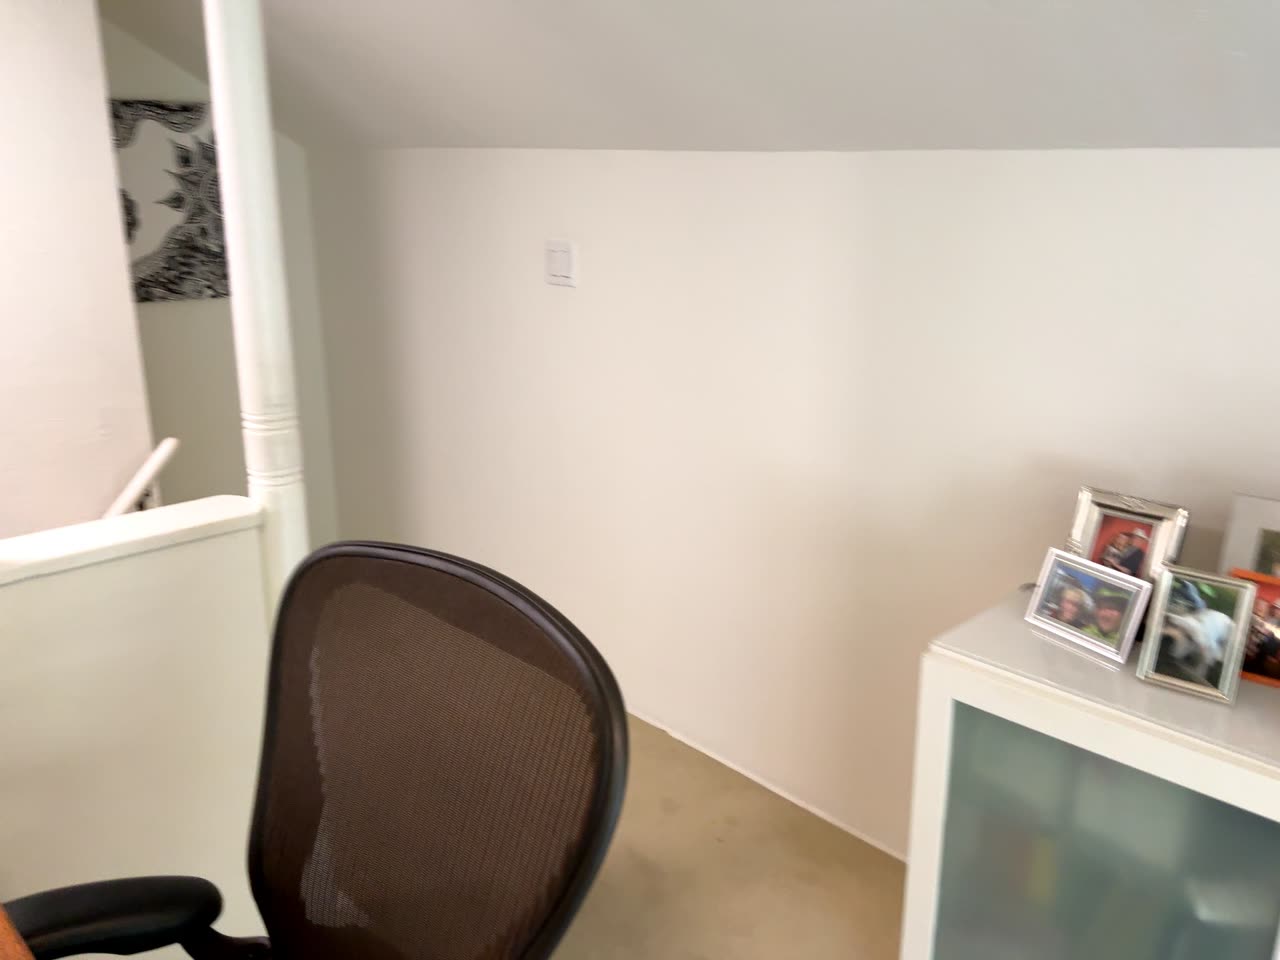
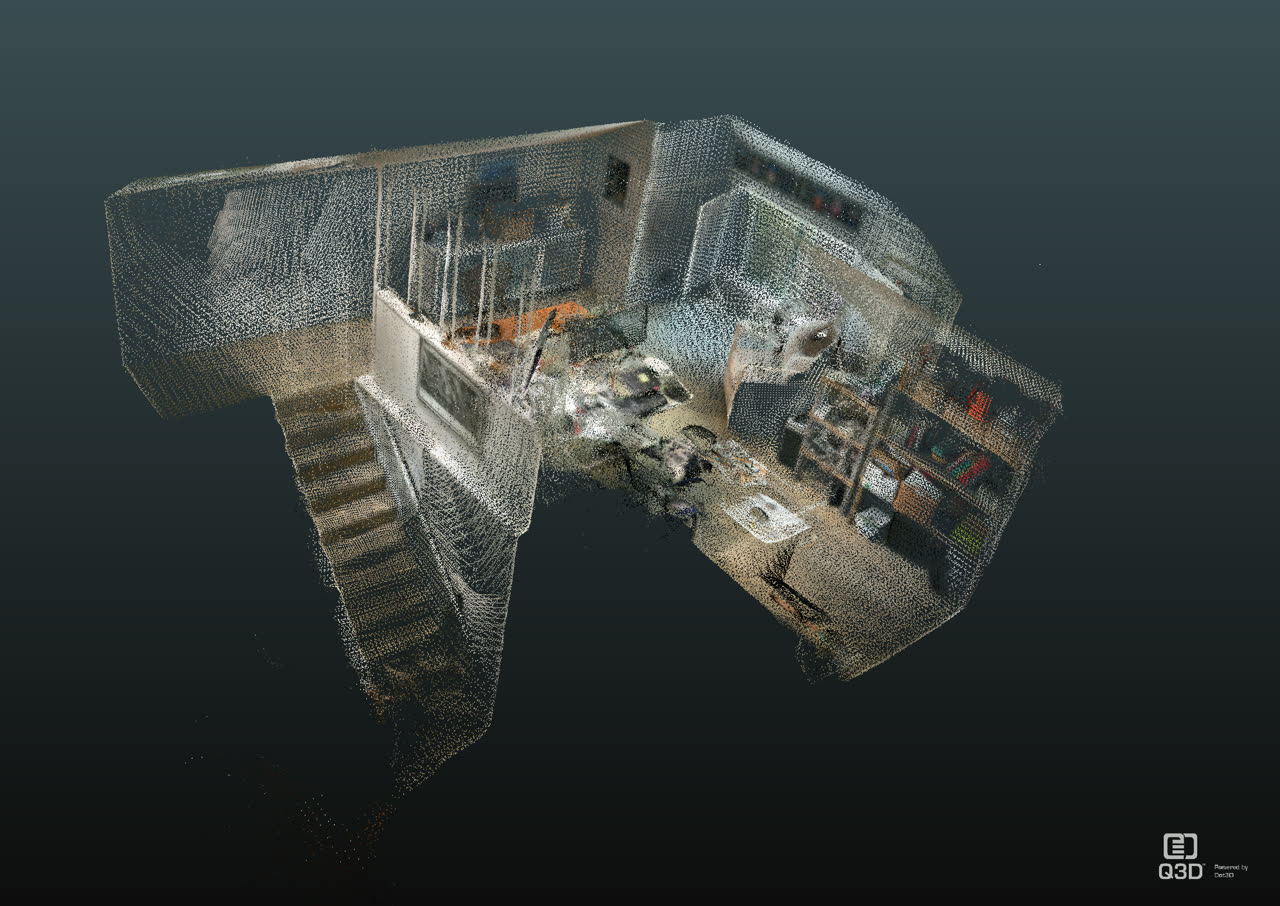
360° captures and point clouds of real environments (home, office, a postal facility in the Bay Area) for scene understanding and simulation reconstruction.
5 examples in this sample pack. Short clips below are cut from the actual capture; the full pack is delivered from Realset's bucket with temporary credentials.
What a formal batch of this modality delivers.
| Capture | 360° consumer camera raw + stitched; iPad LiDAR depth frames + RGB frames with intrinsics |
|---|---|
| Outputs | PLY point cloud and E57 scan per scene |
| Use | Scene reconstruction, sim asset building |
Delivered from an S3-compatible bucket. Credentials are issued per client, sent separately, and expire; one command pulls everything and resumes if interrupted.
aws s3 sync s3://<bucket>/<prefix>/ ./sample/ --endpoint-url <endpoint> --profile realset
Liked what you saw? Tell us the task family, volume and format. We reply with a scoped batch and a quote; delivery terms are settled at order time.
Three questions. We reply within one business day with a sample set and a quote.